About Me
Welcome! I am currently a Ph.D. student in Computer Science at the Academy of Interdisciplinary Studies (AIS), Hong Kong University of Science and Technology (HKUST). Prior to my doctoral study, I received my M.Sc. degree from the Department of Computer Science and Technology, Tsinghua University, supervised by Prof. Huaping Liu, and my B.Eng. degree from Tsien’s Excellence Education Program, Tsinghua University.
My research interest mainly focuses on Multi-modal Large Models Pretraining, VLA Pre-training and Data Auto-labeling & Mixture Optimization for embodied intelligence. My previous work involves the navigation and mobile manipulation in embodied scenarios (AI2-THOR, Habitat et al.). My ultimate goal is to discover generalizable representations for a wide range of robot skills.
I am currently seeking industry or postdoctoral positions in model pretraining and data optimization for embodied intelligence. If you have positions in related areas, please feel free to contact me.
News
- [05/2026] Co-organizing the AgiBot World Challenge 2026 at ICRA 2026!
- [05/2026] Attended the ICRA 2026 with 1 presented poster in Vienna!
- [01/2026] Granted a US Patent on robot control (US 12,521,890).
- [11/2025] Joined AgiBot as an Embodied AI Algorithm Engineer, working on VLA pre-training.
- [10/2023] Attended the IROS 2023 with 2 presented posters in Detroit!
- [08/2023] Working as a research engineer in Lenovo Research.
- [07/2023] Graduated from Tsinghua University with M.Sc. degree in Computer Science.
- [06/2023] Two papers are accepted by IROS 2023.
- [05/2023] Attended the ICRA 2023 with 1 presented poster in London!
Education
- Sep 2024 - Present Ph.D. Student in Computer Science, Academy of Interdisciplinary Studies (AIS), Hong Kong University of Science and Technology (HKUST). Research focus: Multi-modal Large Models Pretraining, VLA Pre-training, Data Auto-labeling & Mixture Optimization.
- Sep 2020 - Jun 2023 M.Sc. in Computer Science, Department of Computer Science and Technology, Tsinghua University. Advisor: Prof. Huaping Liu. Research focus: Robotic Manipulation, Visual Navigation, Imitation Learning.
- Sep 2016 - Jun 2020 B.Eng. in Engineering Mechanics (Tsien’s Excellence Education Program), Tsinghua University.
Experience
- Embodied AI Algorithm Engineer (VLA Pre-training), AgiBot — Nov 2025 - Present, Shanghai / Beijing
- Architected a CoT-VLA pre-training framework based on Qwen3-VL-4B with Chain-of-Thought injection; achieved 97.5% baseline success rate on LIBERO and 95%+ with CoT reasoning.
- Built an automated multi-source data engine (LLM APIs + local models) curating 100k+ industrial and general trajectories with filtering, phase segmentation and multi-modal tagging.
- Validated data mixtures on physical wheeled humanoid platforms for long-horizon industrial/indoor tasks.
- Algorithm Engineer Intern, AgileX Robotics — Jun 2025 - Oct 2025, Shenzhen
- Developed an OpenVLA and Qwen3-VL based dataset evaluation pipeline (tri-view feature fusion, entropy-weighted scoring, SAM 2 segmentation).
- Fine-tuned and deployed pi0.5 base models for tabletop tasks (grasping, folding clothes, sorting) on dual-arm setups.
- Led VLA post-training quantization studies (INT8/INT4, GPTQ, AWQ) benchmarking edge robot deployment.
- Research Engineer (Mobile Intelligence), Lenovo Research — Aug 2023 - Aug 2024, Beijing
- Trained and benchmarked multi-modal perception models for personal smart devices; studied LLaMA-2 compression and quantization for mobile platforms and robotic agents.
- Robotics Algorithm Research Intern, AI Lab, ByteDance — May 2022 - Jul 2023, Beijing (mentored by Dr. Tao Kong)
- Curated large-scale humanoid manipulation pre-training datasets (COCO, Visual Genome, Ego4D) adapted to embodied settings.
- Evaluated vision backbones (CLIP, MoCo-v3, MAE) for VLA models with multi-modal masking and ablation studies.
- Co-designed 3D online scene reconstruction for mobile manipulation service robots, validated in real-world trials.
Research Interests
- Multi-modal Large Models & VLA Pre-training: training vision-language-action foundation models for target robot tasks
- Data Auto-labeling & Mixture Optimization: automated data annotation, data ratio optimization (DRO) for pre-training pipelines
- Embodied Intelligence: visual language navigation, mobile manipulation, scene understanding
Publications and Projects
-
 Research
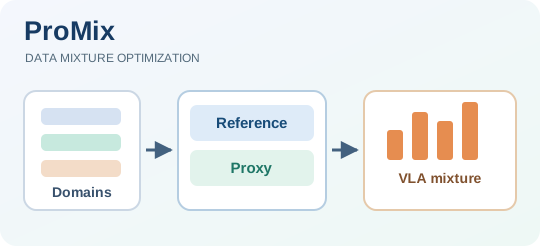
ProMix: Efficient Data Mixture Optimization for Robotic Imitation via Proxy-Reference DROOngoing research, 2026Learns domain mixture weights with a lightweight proxy and frozen reference model, then transfers the weights to VLA training.
-
 ICRA
2024 IEEE International Conference on Robotics and Automation (ICRA), May 2024. Yokohama, Japan
-
 ICRA
2023 IEEE International Conference on Robotics and Automation (ICRA) , May. 2023. London, UK
-
 IROS
2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , Oct. 2023. Detroit, USA
-
 IROS
2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , Oct. 2023. Detroit, USA
-
Scene Graph for Embodied Exploration in Cluttered ScenarioIEEE International Conference on Robotics and Automation (ICRA), 2023ICRA 2023
-
Active Exploration for Answering Questions in Bin ScenariosIEEE/ASME Transactions on Mechatronics (T-MECH) , 2022T-MECH 2022
-
Simultaneous Trajectory Optimization and Force Control with Soft Contact MechanicsIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , 2020IROS 2020
Talks
-
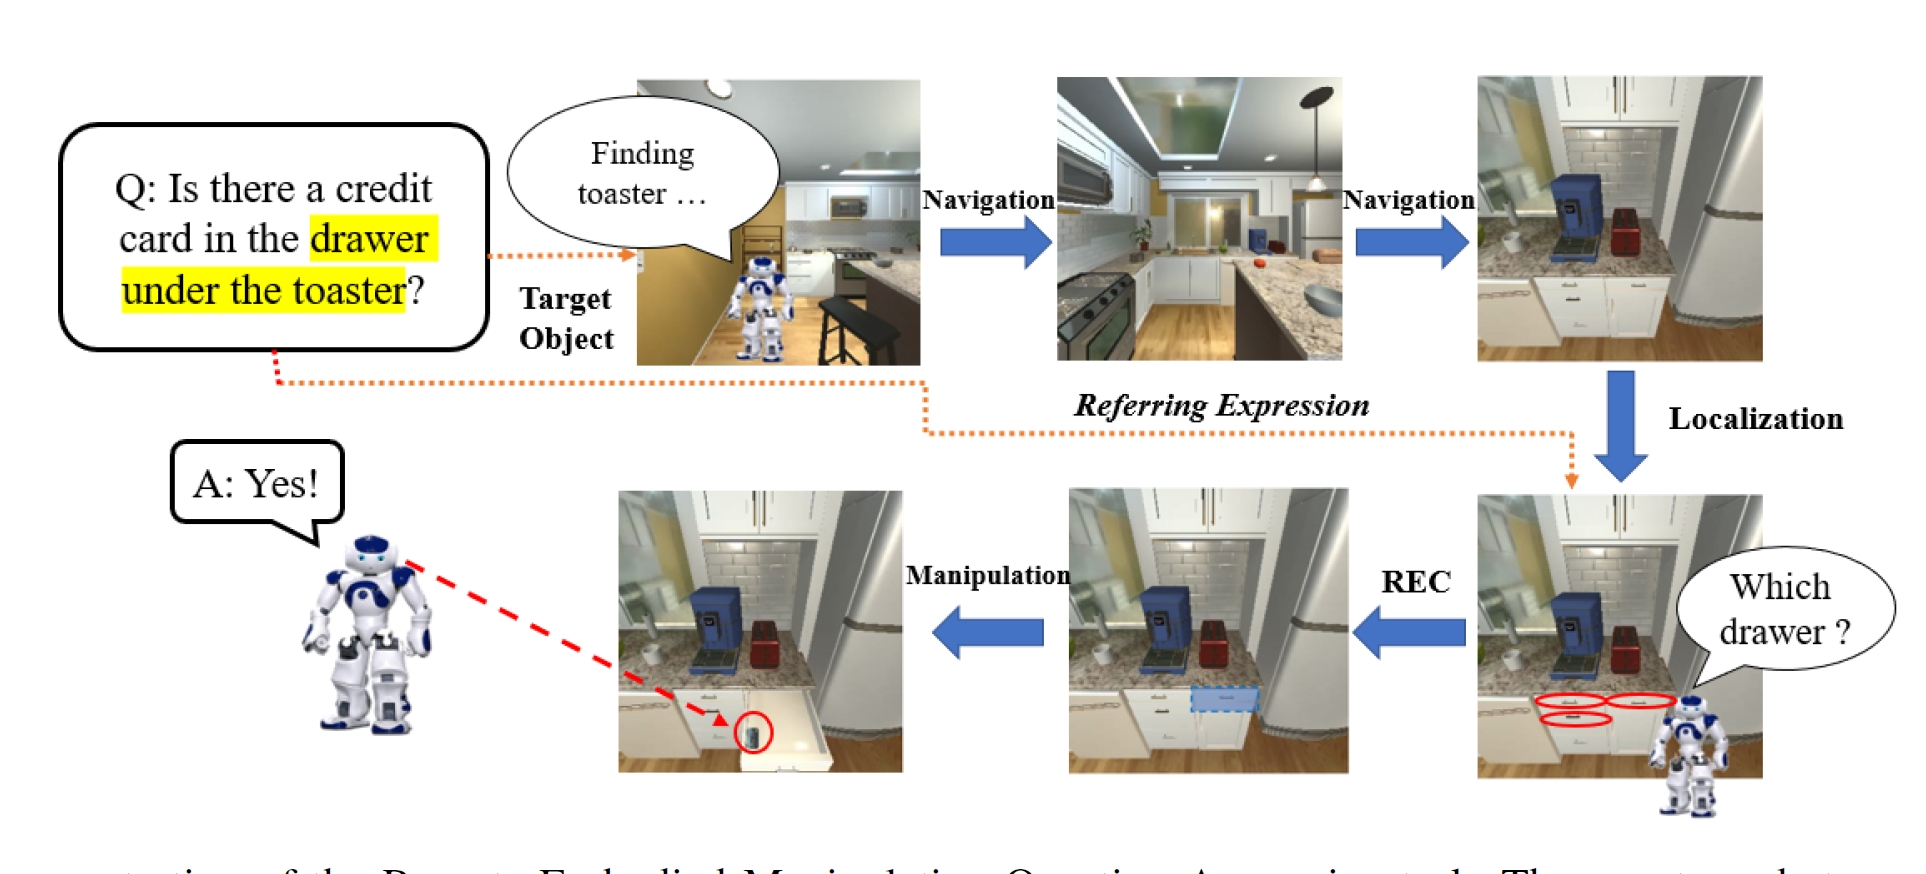 ICRA
the International Conference of Robotics and Automation (ICRA), 2023, London.
-
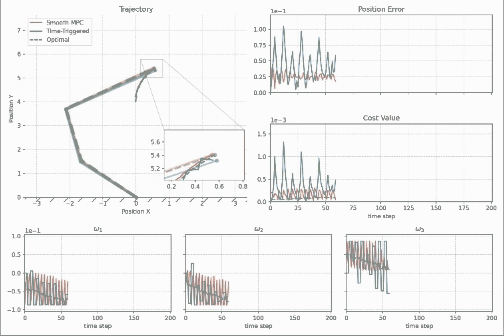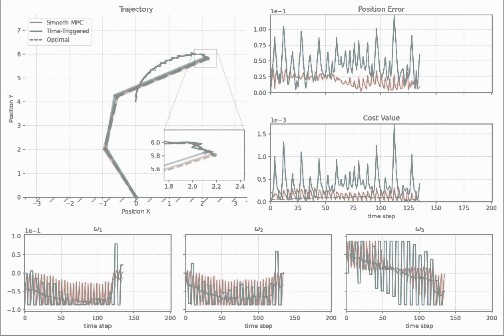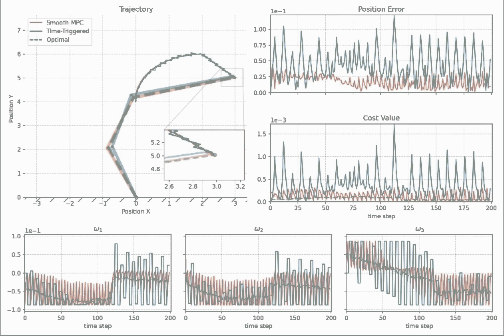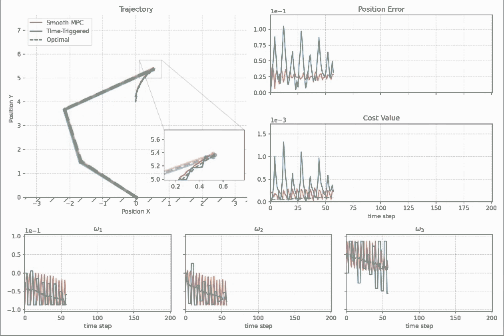 ICRA
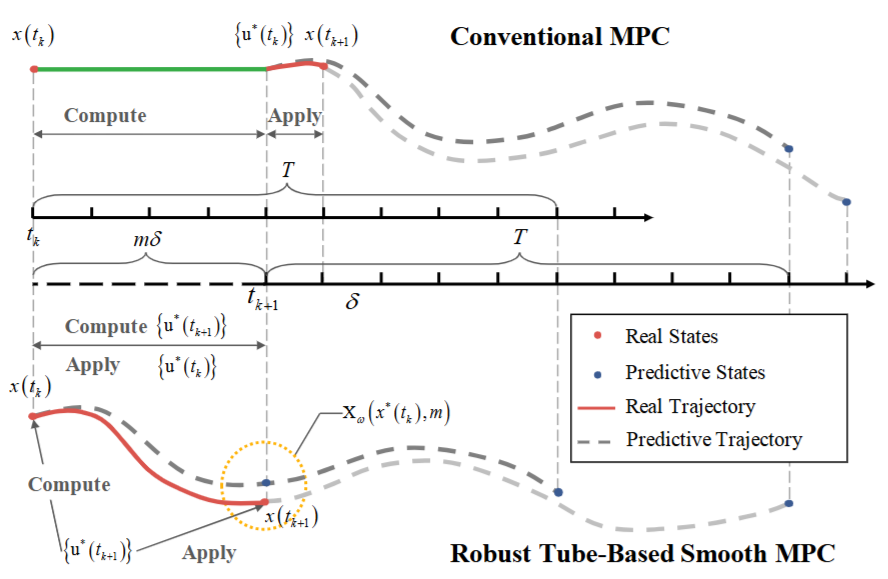
Smooth Computation without Input Delay: Robust Tube-Based Model Predictive Control for Robot Manipulator Planningthe International Conference of Robotics and Automation (ICRA), 2024, Yokohama.Video (MP4) Oral Presentation
Services
- Conference Reviewer: ICRA 2023, 2024, 2025; IROS 2023, 2025; CoRL 2025; HRI 2023
- Competition Organization: Co-organizer of the AgiBot World Challenge 2026 at ICRA 2026
- Oral & Poster Presentations: Oral at ICRA 2024 (Yokohama); Posters at ICRA 2026 (Vienna), ICRA 2023 (London), IROS 2023 (Detroit), IROS 2020 (Online); Oral at ECSSMET 2018 (Netherlands)
- Membership: IEEE RAS, IEEE CIS student member
- Journal Reviewer: IEEE RA-L
- Teaching Assistant: Introduction to Intelligent Robotics Fall 2022, instructed by Prof. Huaping Liu
Resources